← All workFormula Student Driverless · 2024–26
Auria: simulation and control for a driverless car
My work within Auria's autonomous software team, from simulator bridges to the Trackdrive controller that drove the car around the circuit in competition.
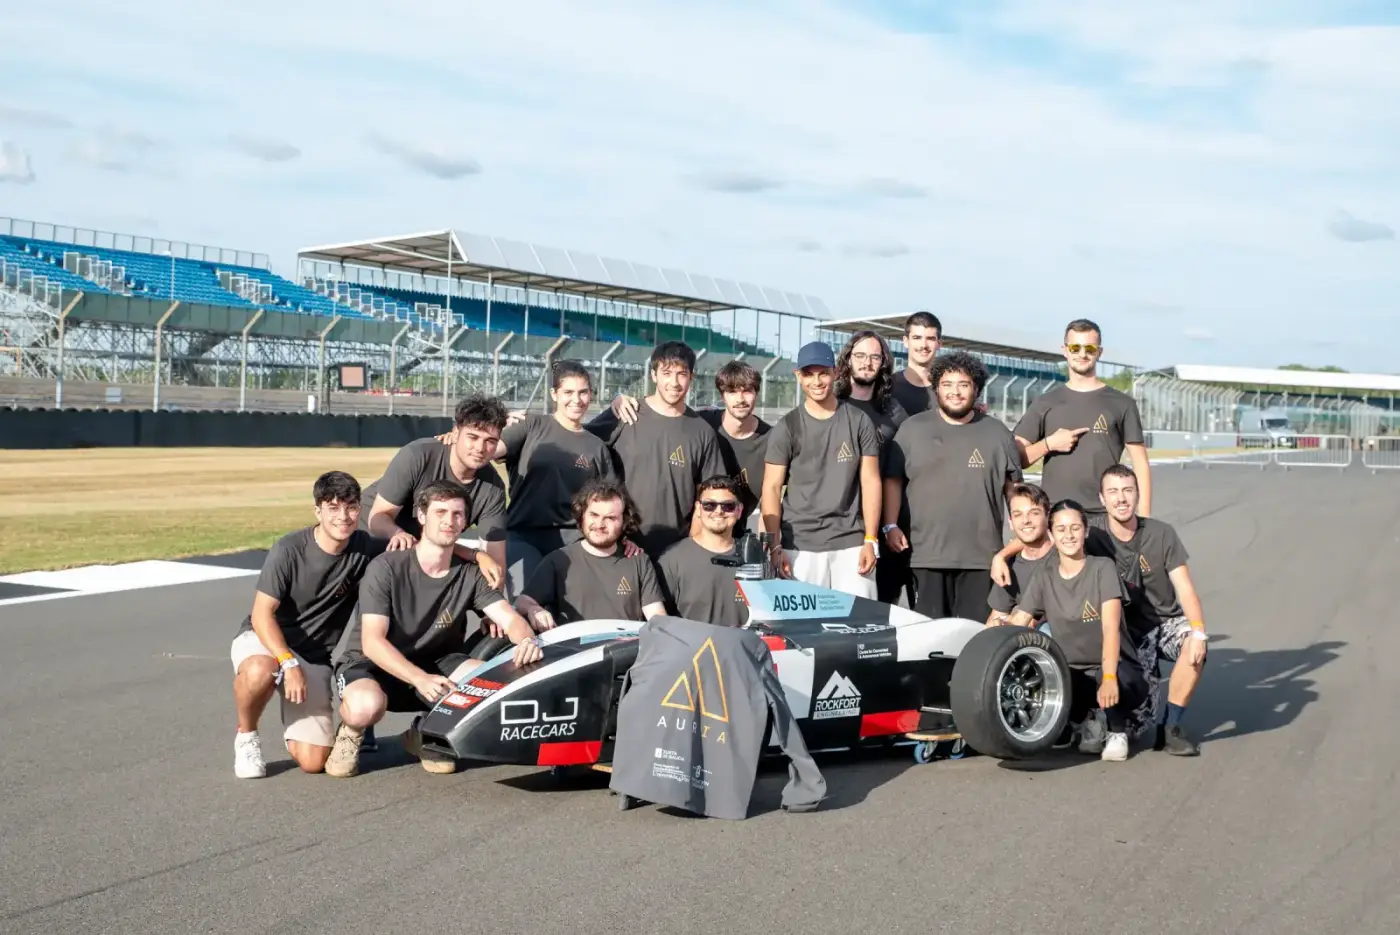
Formula Student Driverless is a student competition where the car has to drive itself around a circuit marked only by cones. Blue on the left, yellow on the right, orange at the start and finish.
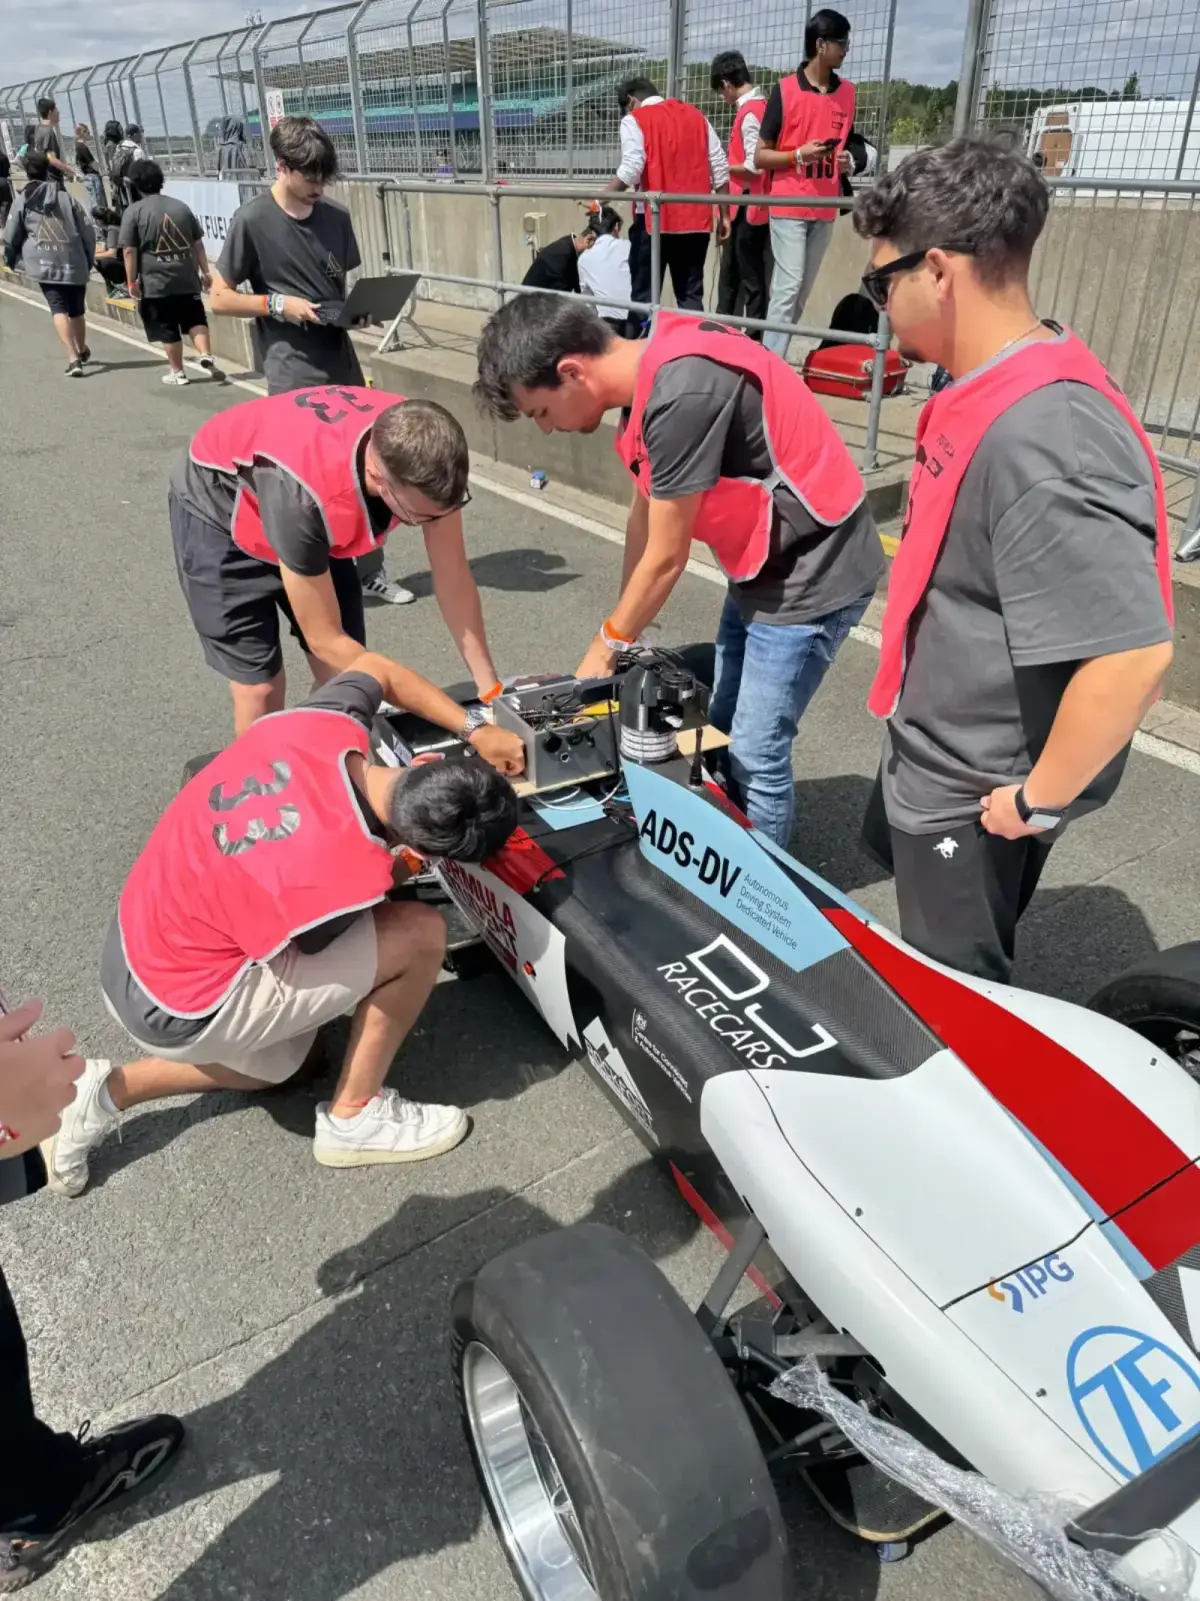
I spent two seasons in Auria’s autonomous software team. The car brings together perception, localisation, planning, control and vehicle interfaces developed by the team. My individual work centred on simulator integration, the Trackdrive controller and the CAN bus port from ROS to NATS.
Trackdrive on the real car
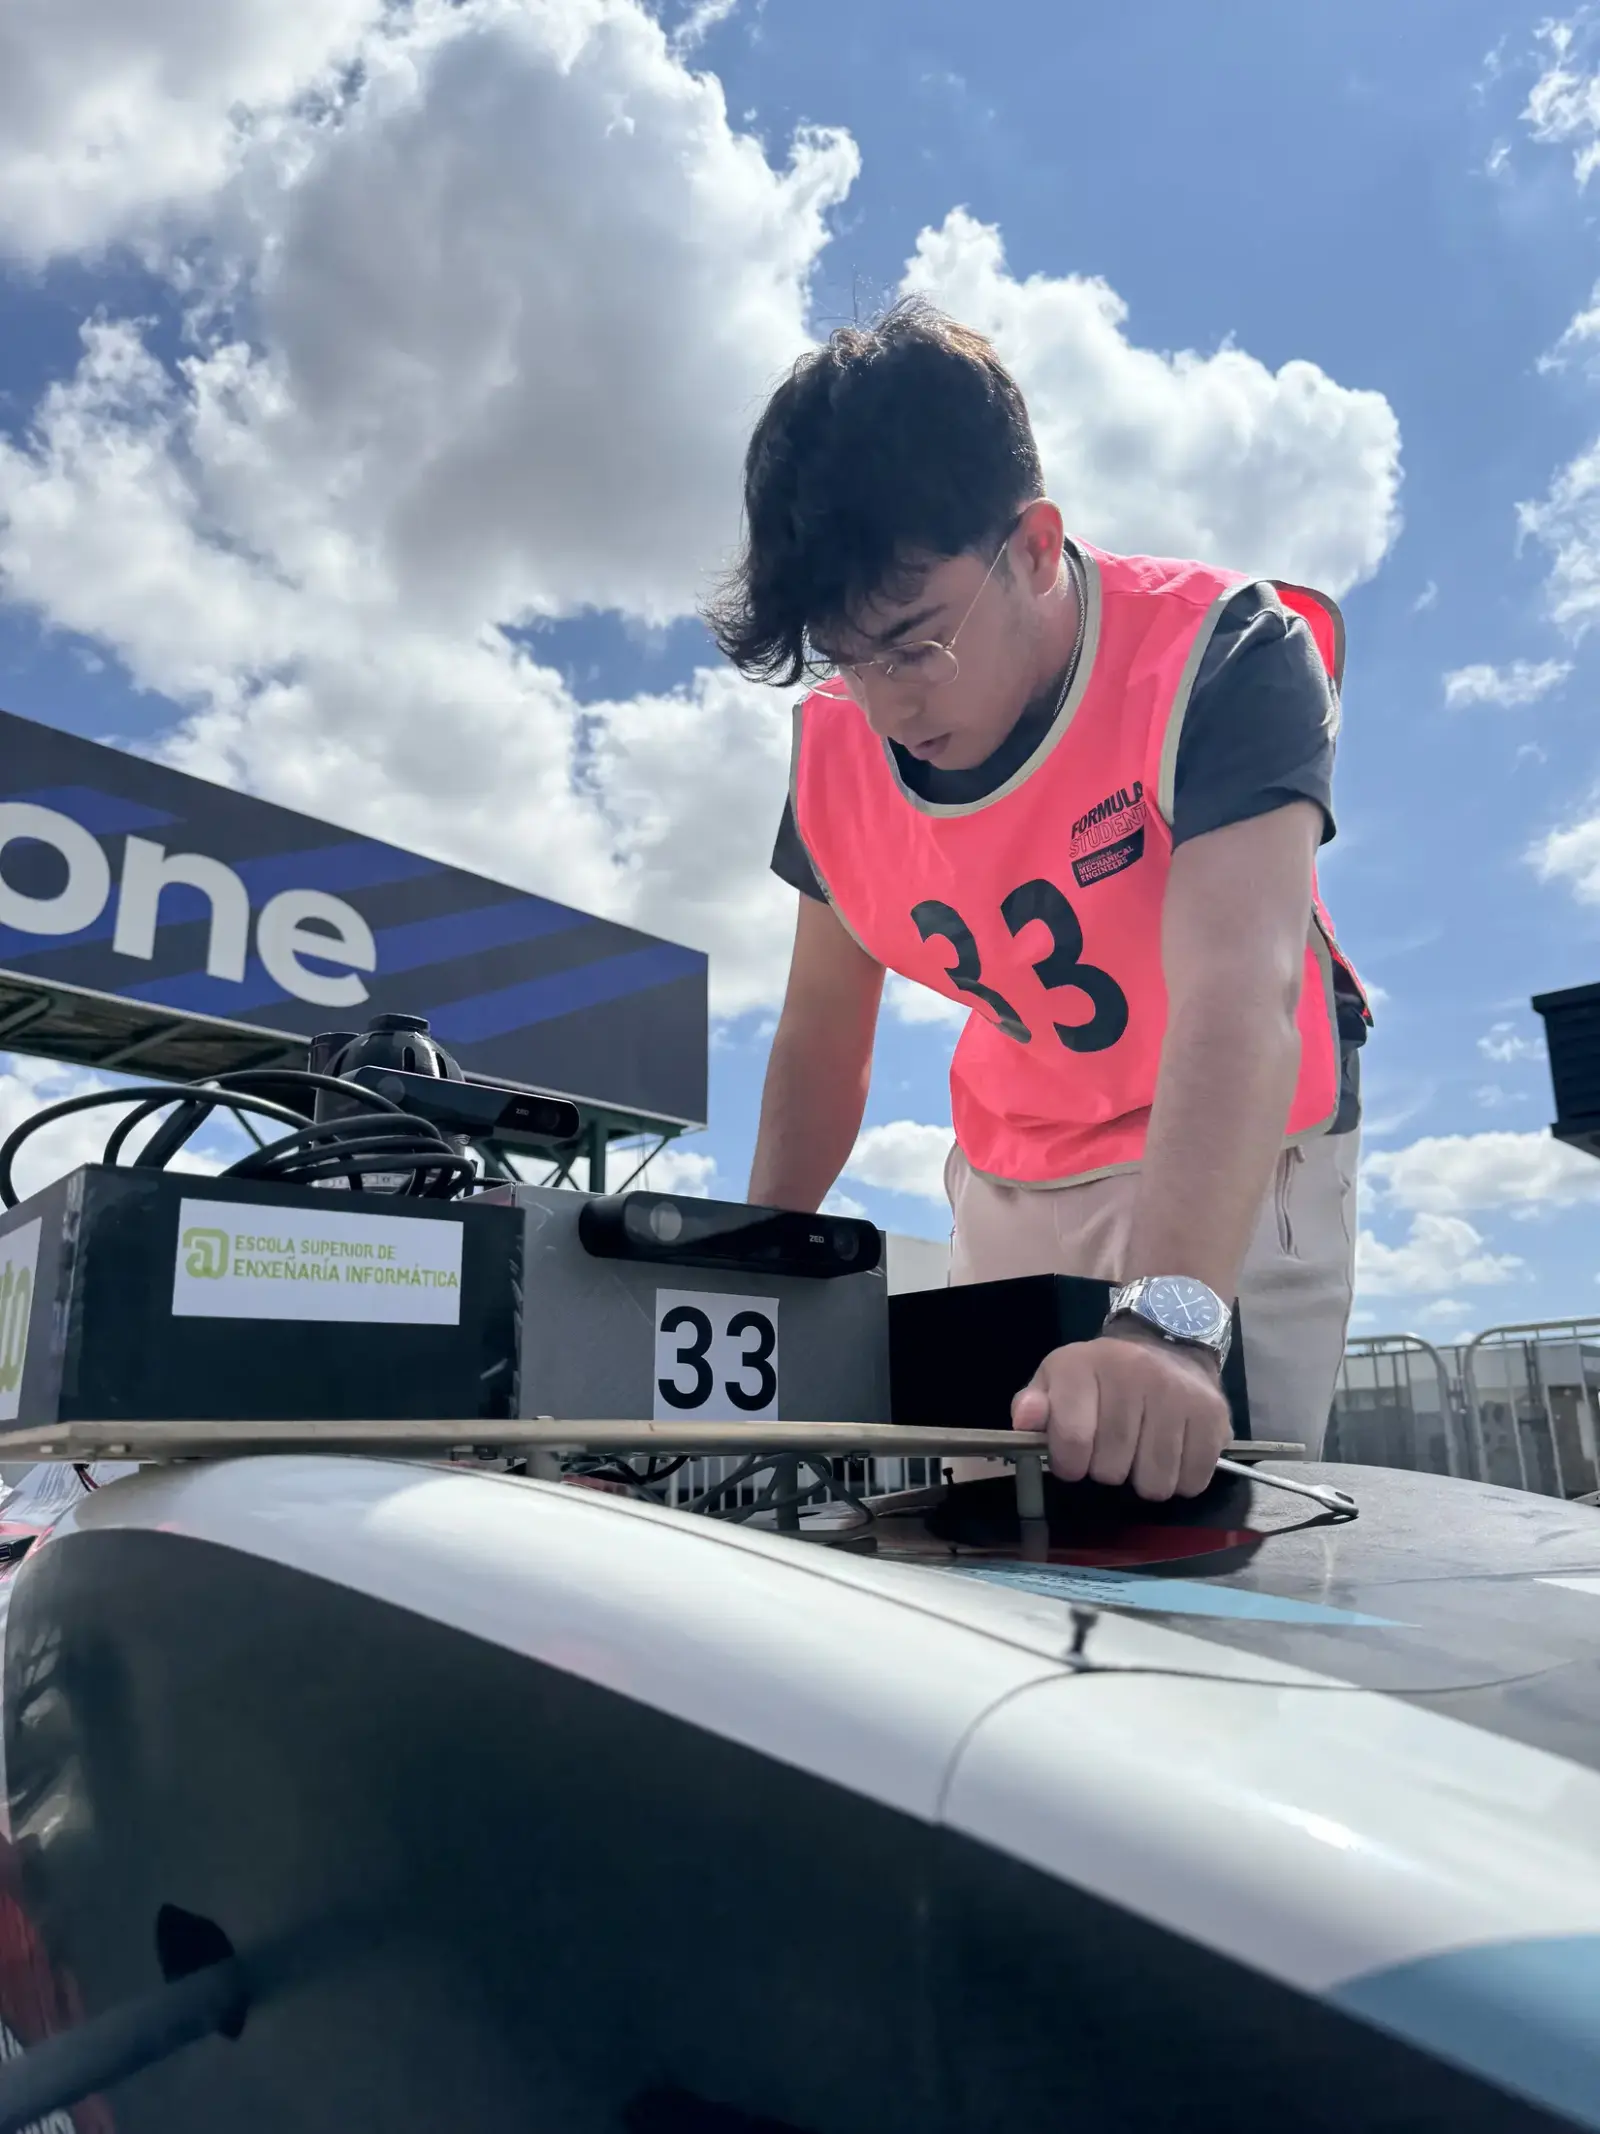
I developed the Trackdrive controller that enabled the car to complete laps in competition. It turns the corridor between the cones into steering and speed commands, with checks for stale inputs and the vehicle’s driving state. It runs as part of the team’s autonomous stack.
I also ported the CAN bus interface from ROS to NATS, connecting vehicle state and control commands to the team’s messaging system.
Connecting the simulators
CarMaker is IPG’s vehicle simulator. I built bridges so we could run our autonomous system inside it and took part in the Lap Time Simulation (LTS) competition, where the team finished third.
EUFS Sim 2 was developed by Edinburgh University Formula Student. I adapted it to communicate with Auria over NATS, packaged a reproducible runtime and integrated Rerun so we could inspect the simulated car, cones and trajectory. The simulator and the team’s autonomous stack are the foundations of that integration.
Both integrations connect a simulator to the team’s software. My work was the bridge between them, the runtime needed to launch it and the tools to observe what happened during a run.
Helping the team contribute
I wrote contribution guidelines and engineering documentation covering development workflows, messaging contracts and integration boundaries. This gave contributors a shared reference for how to work within the repository.
At Formula Student UK 2026, the team finished 11th of 42. Since September 2026, I’ve continued as an advisor.
Try the controller
This browser simulation follows the same idea as the car: see the cones, plan through the gates, then steer with pure pursuit. Change the lookahead and corner speed to see how the line and lap time change. It’s a simplified demonstration, not a replay of competition telemetry.
- Lap
- 0:00.00
- Speed
- 0 km/h
- Your best
- No lap yet
- My lap, ghost car
- No lap yet
Steering command±24°